VisTacAlign: Co-Training Dexterous Policies on Tactile Human and Robot Demonstrations
arXiv · September 2026
Learning Humanoid Navigation From Human Data
IEEE Robotics and Automation Letters (RA-L) · July 2026
TensorTouch: Calibration of Tactile Sensors for High Resolution Stress Tensor and Deformation for Dexterous Manipulation
IEEE Transactions on Robotics · April 2026
Sparse Autoencoders Reveal Interpretable and Steerable Features in VLA Models
Accepted into CoRL 2026 · March 2026
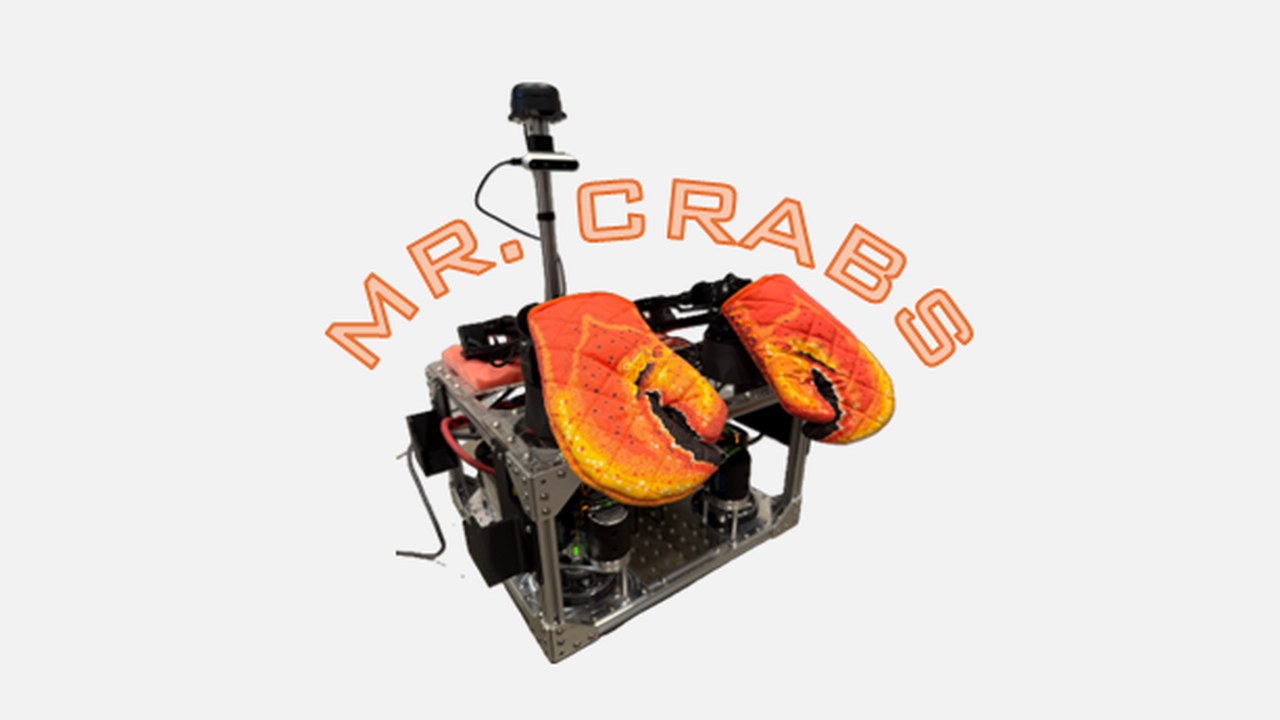
MR. CRABS: Mobile RGB-D Camera-LIDAR Robot for Autonomous Bimanual Manipulation & Sensing
ICRA 2026 Workshop on Act to Sense to Act Better · June 2026
DOT-Sim: Differentiable Optical Tactile Simulation with Precise Real-to-Sim Physical Calibration
IEEE ICRA 2026 · May 2026
🍓 DexFruit: Dexterous Manipulation and Gaussian Splatting Inspection of Fruit
IEEE Robotics and Automation Letters (RA-L) · December 2025
A Control Barrier Function for Safe Navigation with Online Gaussian Splatting Maps
International Conference on Robotics and Automation (ICRA) · May 2025
Next Best Sense: Guiding Vision and Touch with FisherRF for 3D Gaussian Splatting
International Conference on Robotics and Automation (ICRA) · January 2025
ProACT: An Augmented Reality Testbed for Intelligent Prosthetic Arms
IEEE Transactions on Neural Systems and Rehabilitation Engineering · January 2025
Understanding and Imitating Human-Robot Motion with Restricted Visual Fields
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025 · November 2025
Dynamic Layer Detection of Thin Materials using DenseTact Optical Tactile Sensors
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) 2025 · October 2025
Facial Haptic Feedback for Robotic Prostheses
Converging Clinical and Engineering Research on Neurorehabilitation V · December 2024
Touch-GS: Visual-Tactile Supervised 3D Gaussian Splatting
Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) · October 2024
DenseTact-Mini: An Optical Tactile Sensor for Grasping Multi-Scale Objects From Flat Surfaces
International Conference on Robotics and Automation (ICRA) · May 2024
Embedded Object Detection and Mapping in Soft Materials Using Optical Tactile Sensing
SN Computer Science · March 2024
Inter-finger Small Object Manipulation With DenseTact Optical Tactile Sensor
IEEE Robotics and Automation Letters · November 2023
The role of collaborative robotics in assistive and rehabilitation applications
Science Robotics · October 2023
Diffusion Co-Policy for Synergistic Human-Robot Collaborative Tasks
IEEE Robotics and Automation Letters · November 2023
It Takes Two: Learning to Plan for Human-Robot Cooperative Carrying
2023 IEEE International Conference on Robotics and Automation (ICRA) · May 2023
Trajectory and Sway Prediction Towards Fall Prevention
2023 IEEE International Conference on Robotics and Automation (ICRA) · May 2023
DenseTact 2.0: Optical Tactile Sensor for Shape and Force Reconstruction
2023 IEEE International Conference on Robotics and Automation (ICRA) · May 2023
DenseTact: Optical Tactile Sensor for Dense Shape Reconstruction
International Conference on Robotics and Automation (ICRA) · May 2022
Replay Overshooting: Learning Stochastic Latent Dynamics with the Extended Kalman Filter
2021 IEEE International Conference on Robotics and Automation (ICRA) · May 2021
Recent Development in Human Motion and Gait Prediction
RSS 2020 Workshop RobRetro · June 2020
Modeling And Control For Robotic Assistants: Single And Multi-Robot Manipulation
University of Pennsylvania · May 2019