Professor
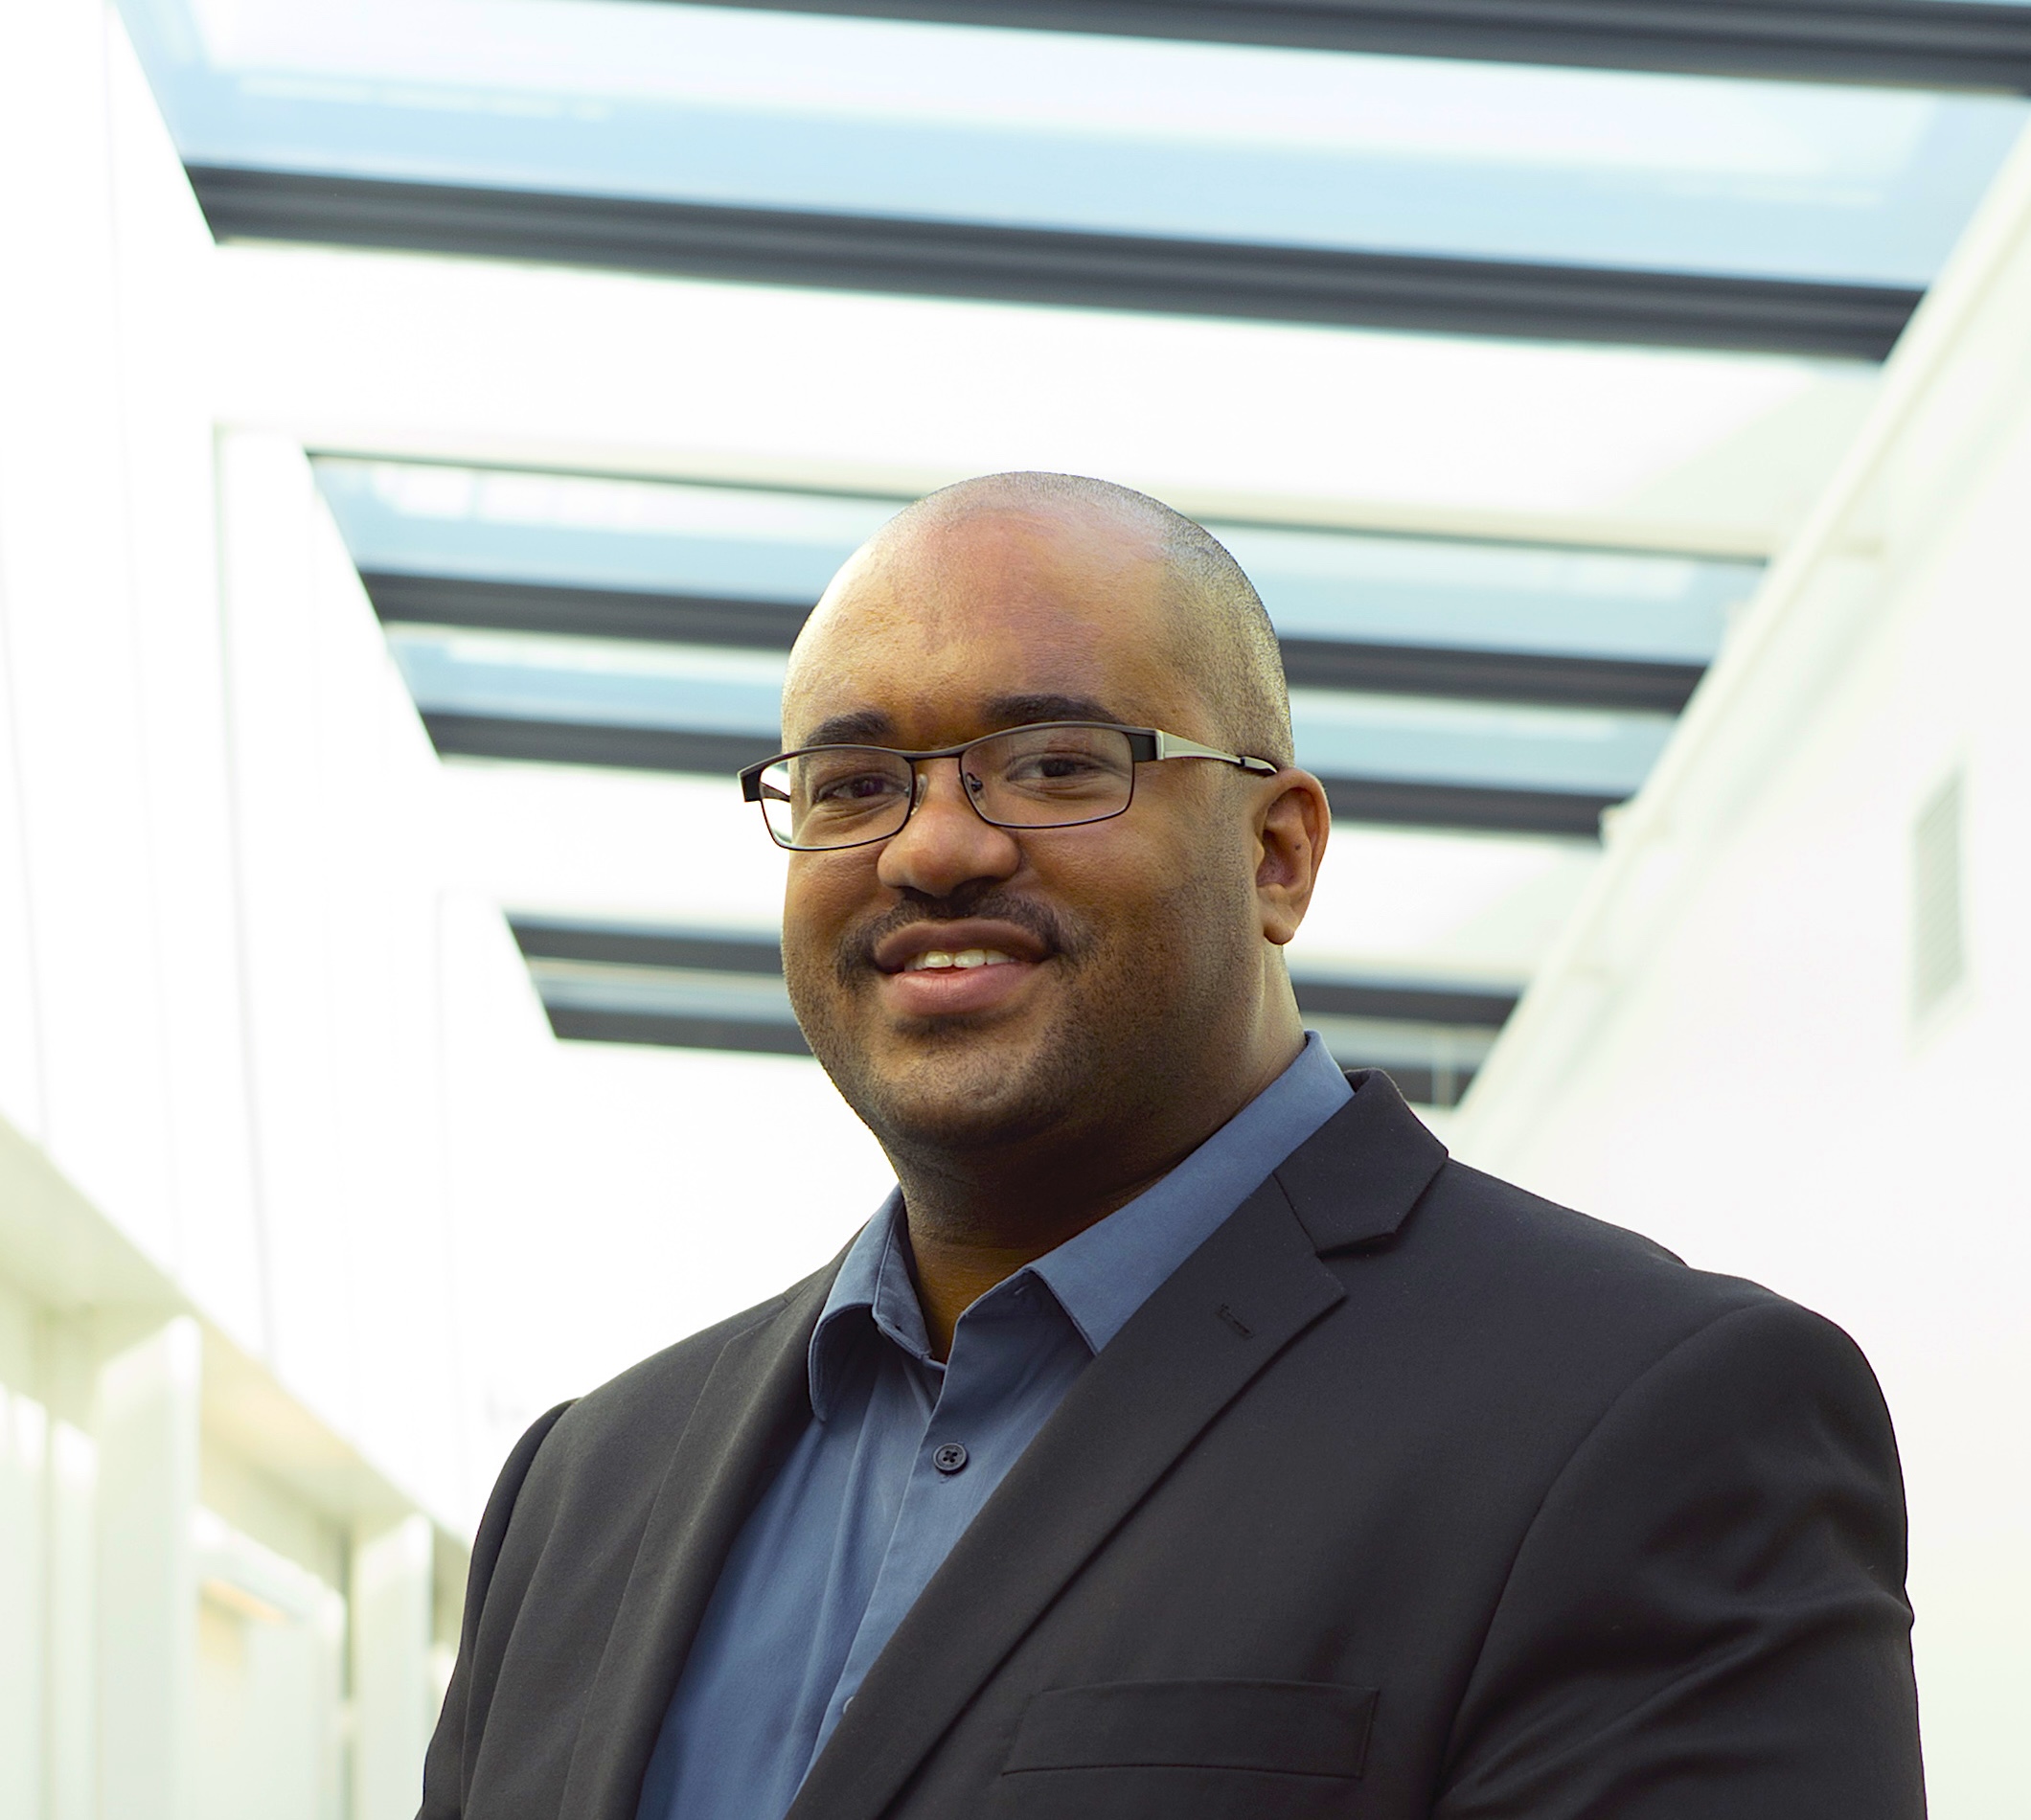
Monroe Kennedy III is an Assistant Professor of Mechanical Engineering and by courtesy, of Computer Science and a recipient of the NSF Faculty Early Career Award. His area of expertise is in collaborative robotics, specifically intent estimation for robot teaming and in dexterous robotic manipulation.
Postdocs
Shivani is a postdoctoral scholar at the Stanford Robotics Center, working with older adults experiencing upper limb disabilities on the design of robotic tools to support everyday activities at home. She is a part of the Stanford Older Adult Robotics project led by Dr. Michelle Baldonado, and is advised jointly by Prof. Karl Lorenz and Prof. Monroe Kennedy.
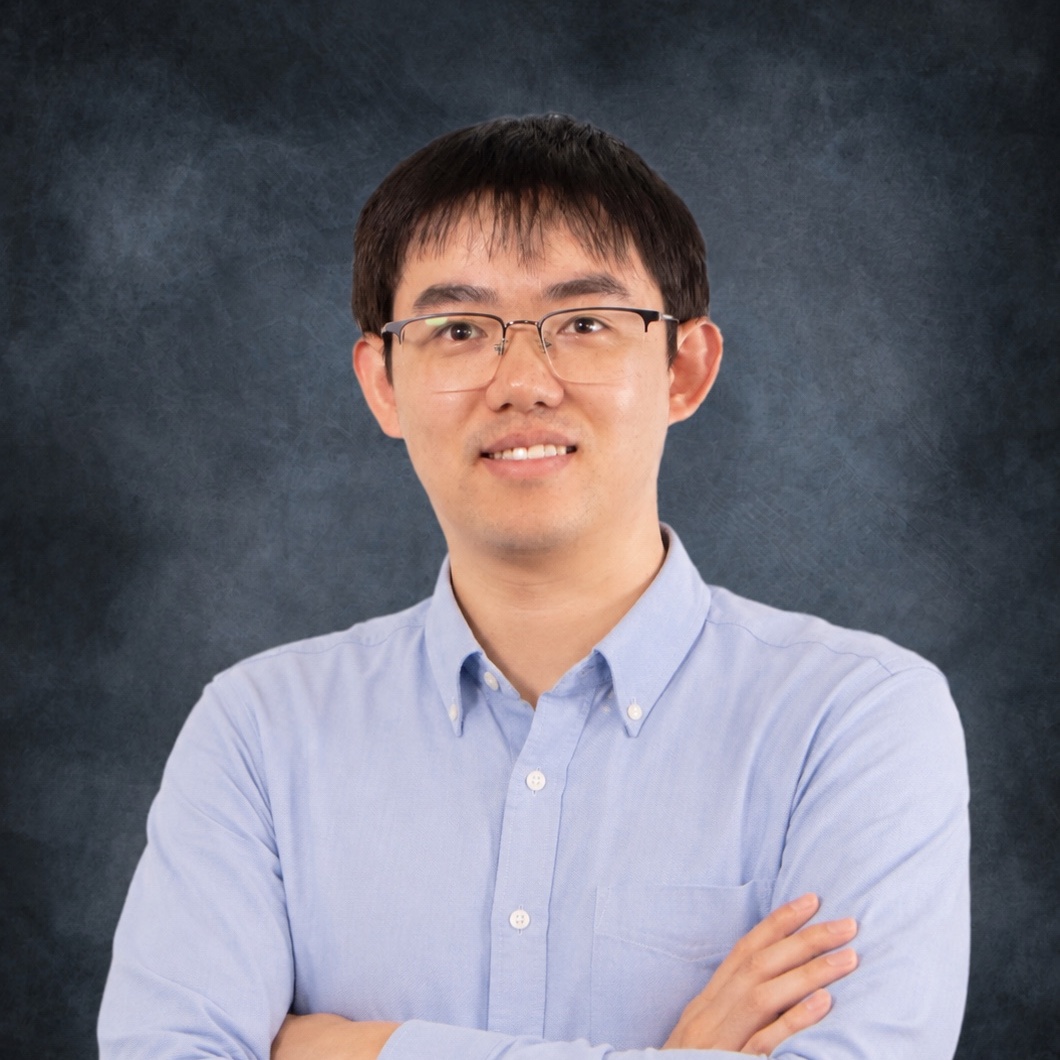
Yanda Yang is a postdoctoral scholar in the ARMLab, working on autonomous robotic systems, magnetic micro/milli-robotics, motion planning, and feedback control. His research develops learning- and model-based methods for robotic autonomy in complex biomedical environments, with applications in magnetic robotic manipulation and endovascular intervention.
PhD Students
Matt Strong is a Computer Science PhD student in the ARMLab and a recipient of the NSF Graduate Fellowship. His interests are in building autonomy and perception for human-robot interaction through visual-tactile sensing and EEG brain interfaces. He previously worked at Microsoft as a Software Engineer, and before that was an undergraduate researcher at the University of Colorado Boulder under Professor Alessandro Roncone, where he worked on close-proximity human-robot interaction. In his free time, he likes to run, play basketball, and drive his Corolla.
Aiden is a Ph.D. student in the ARMLab in Mechanical Engineering and a recipient of the NSF Graduate Research Fellowship and the Stanford Graduate Fellowship. Broadly, his research interests are dextrous manipulation, neural object state representations, and next-generation optical touch sensors for robotics. Aiden previously conducted research on safety-critical control for high-speed quadcopters in the AMBER lab at Caltech. Outside of research, Aiden loves camping, running, and watching F1.
Jinho So is a Ph.D. student in the ARMLAB in Mechanical Engineering. He is interested in tactile sensing, dexterous manipulation, and utilizing robots in industrial areas for both safety and efficiency. He worked at Samsung Electronics on adapting robots for the automation of hazardous tasks.
Max Burns is a Ph.D. student in Mechanical Engineering and a recipient of the NSF and Stanford Graduate Research Fellowships. He is interested in developing intelligent lower limb exoskeletons to improve the mobility of people suffering from balance or gait impairments. Max’s previous research with the MIT Newman Laboratory used an instrumented walking cane to estimate postural sway velocity in older adults.
Shalika Neelaveni is a Mechanical Engineering PhD student in the ARMLab and the recipient of the Stanford Graduate Fellowship. She is interested in exploring smart materials for applications in power, sensing, and actuation to improve robot dexterity. Her previous research included developing a soft tactile sensor for soft robotic grippers as an undergraduate researcher at the University of Pennsylvania, under Professor Kevin Turner. Outside of the lab, she loves to aimlessly walk around new cities, lift at the gym, and wear her Crocs.
Maisha Khanum is a Ph.D. student in Mechanical Engineering and a recipient of the NSF Graduate Research Fellowship. She is interested in perception-based planning and adaptive control strategies to enhance the functionality of exoskeletons in complex, real-world terrains. She previously worked on icy surface locomotion in the Extreme Environment Robotics Group at JPL and fully actuated robotic hands in the AMBER lab at Caltech. Outside of the lab, Maisha enjoys working on art projects and building knock-off Legos.
Judith Brown is a Ph.D. student in Mechanical Engineering and a recipient of the NSF Graduate Research Fellowship. Her background is in nonlinear dynamics and mechanics and her research interests focus on utilizing neuromorphic computing for robotic control and manipulation.
Ankush is a Ph.D. student in Mechanical Engineering. Ankush recieved is B.S. in Electrical Engineering at Stanford University specializing in Information Systems and Physical Technology. He is interested in electromechanical systems, hardware design, and robotics, and enjoys making and designing things from the ground up. With the ARMLab, he is working on advancing tactile sensing for robotic manipulation.
Yunxin Fan is a PhD student advised by Prof. Nikolas Blevins, co-advised by Prof. Kennedy. Her work is in modeling and simulating soft objects for surgical applications.
Cindy Huang is a Mechanical Engineering PhD student in the ARM Lab and a recipient of the Stanford Graduate Fellowship. Her research interests are in dexterous manipulation and perception-based control, with a focus on developing autonomous robotic systems that address real-world human needs. Before coming to Stanford, she worked on vision-based control for glass additive manufacturing at Notre Dame and underwater robot design at Purdue. Outside of research, she enjoys snowboarding, going to the gym, and traveling.
Master's Students
Sanjith is a mechanical engineering MS student with a BS in mechanical engineering from UCLA. His interests include hardware design, mechatronics, and robotics. Outside of research, Sanjith enjoys playing basketball, watching sports, and watching movies.
Shreya is an M.S. student in Computer Science at Stanford, interested in human-robot interfaces that translate human intent into robot motion for medical applications. She earned her B.S. in Computer Science at Carnegie Mellon University, where she worked on developing brain-computer interfaces to help paralyzed patients communicate and building a voice-controlled surgical robot assistant. Outside of research, Shreya enjoys running, singing, and creative writing.
Uzma Hamid is an M.S. Computer Science student at Stanford University specializing in Artificial Intelligence. Her research interests lie at the intersection of machine learning, computer vision, and robotics, particularly robotic perception and manipulation, human-robot collaboration, and intelligent systems for healthcare and other real-world applications. She is especially interested in building learning-based robotic systems that can robustly perceive, reason about, and interact with complex environments while collaborating with humans.
Adam Sabet is an M.S. student in Electrical Engineering at Stanford University, focusing on robotics and autonomous systems. His research interests include assistive robotics, robotic manipulation, and intelligent systems that combine learning, perception, and control to help people. His previous work includes reinforcement learning and neural networks, the development of a 3-DOF robotic arm, and embedded autonomy and systems engineering as the Project Manager for Ohio State’s NASA Student Launch Initiative.
Undergraduate Students
Ahmed is a Mechanical Engineering Undergraduate specializing in Dynamic Systems and Controls. He is interested in human-robot interactions, soft robotics, and design for accessibility and sustainability.
Angelina is a Mechanical Engineering undergraduate student specializing in Robotics and Automation. She is interested in soft robotics, human-centered design, and sustainability. Within the ARMLab, she is working on using the DenseTact for dexterous manipulation tasks in agricultural robotics. During her free time, she enjoys baking, crocheting, and playing music.
Ethan is a Mechanical Engineering undergraduate specializing in Dynamic Systems and Controls. He is interested in robotics, mechatronics, and sustainability. Outside of the lab, Ethan enjoys playing sports and different instruments.
Denzel is a Mechanical Engineering undergraduate specializing in Dynamic Systems and Controls. He's interested in robotic dexterity, assistive technology, and applying engineering to solve sustainability problems. In his free time, he loves cooking, reading comic books, and collecting LEGO sets.
Lilian is a Mechanical Engineering undergraduate interested in mechanical design, dynamics and controls, biomechanics, and robotics. She is particularly interested in applying these fields to surgical and assistive robotic systems and rehabilitation technologies. In her free time, she enjoys swimming, cooking, and hiking.
Ayaan is a Mechanical Engineering undergraduate specializing in Robotics and Automation and a coterminal master’s student in Computer Science. He is interested in robotic perception, teleoperation, and the application of robotics in assistive technology. In his free time, he enjoys swimming, playing pickleball, and fishing.
Jacob is an undergraduate interested in robotics, mechatronics, and robot autonomy. In his free time he enjoys playing tennis, being outdoors, and reading.
Ryan is a Design undergraduate specializing in Physical Design and Manufacturing. He is interested in using human-centered design and assistive technology to make environments more accessible. In his free time, Ryan enjoys photography, music, and drawing.
Faith is an Electrical Engineering undergraduate interested in robot learning, tactile sensing, and assistive robotics. Within the ARMLab, she is working on collecting visual and tactile demonstration data for dexterous imitation learning. Before joining the lab, she built a pair of SO-101 robot arms and used them to study a contact-rich insertion task.
Yameen is a computer science student at Stanford interested in robotic vision, specifically how robots can select informative views to build 3D reconstructions efficiently. Outside of research, he enjoys making music with friends and hiking
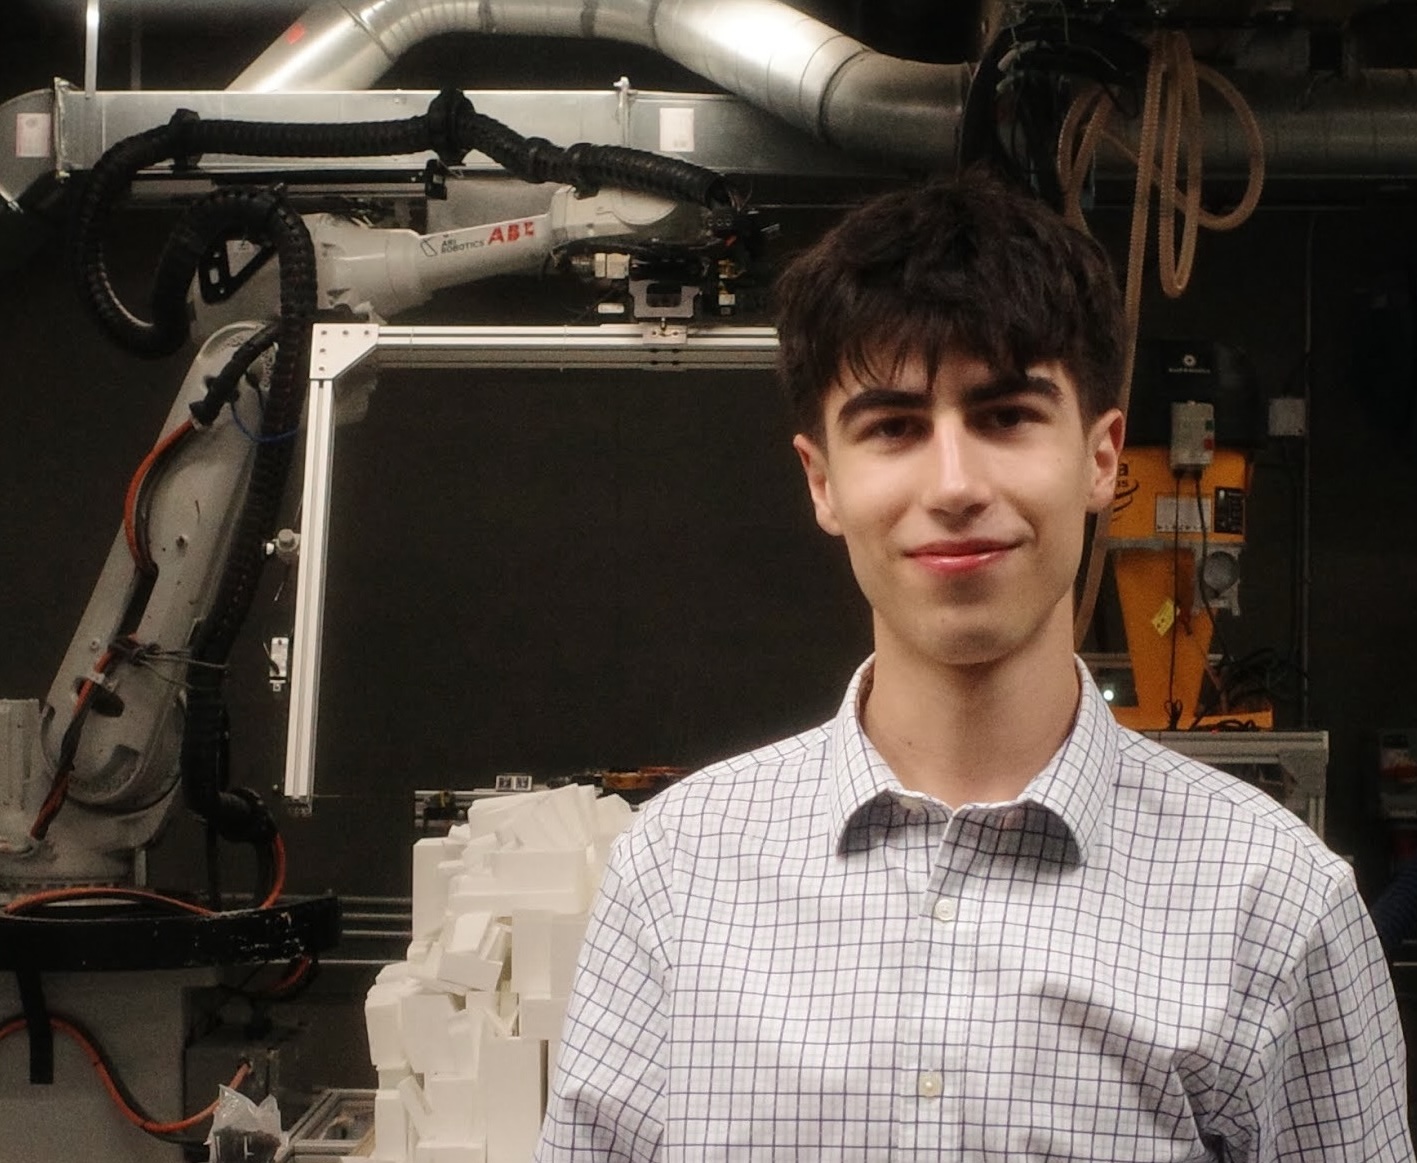
Maximo is a Mechanical Engineering undergraduate focusing on robotics and controls. He’s especially interested in robotic legged locomotion & manipulation, passive dynamics, modeling systems, and first-principles design. In his free time, he loves to build robots in his garage, play soccer, make art, and listen to music.
PhD and Postdoc Alumni
Graduated in 2025, PhD. Thesis title "Improving Robotic Dexterity With Optical Tactile Sensor DenseTact".
Graduated in 2026, PhD. Knight-Hennessy Scholar, Wu Tsai Human Performance Alliance fellow. Thesis title "Task Space Approaches to Simplify the Operation of Robotic Upper Limb Prostheses".
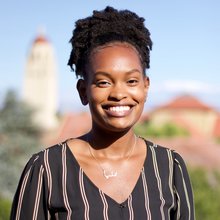
Graduated 2026 PhD. NSF GRFP recipient. Thesis title "Augmented Interfaces for Non-expert Robotic Teleoperation and Human-Robot Interaction".
Graduated 2026 PhD. Thesis title "Learning for Long-Horizon Humanoid Autonomy".
Graduated 2023, PhD. NSF GRFP reciepient. Thesis title "Long-Horizon Prediction for Human-Robot Collaboration".
MS and Undergraduate Alumni
Aditya is an MS student in Mechanical Engineering. He is interested in Robot Manipulation, Motion Planning and Computer Vision concepts.
Visiting MS scholar 2023. Worked on shared autonomy in safe vehicle control handover
MS Alumni 2024-25. Worked on object property identification through robot exploration.