← All people
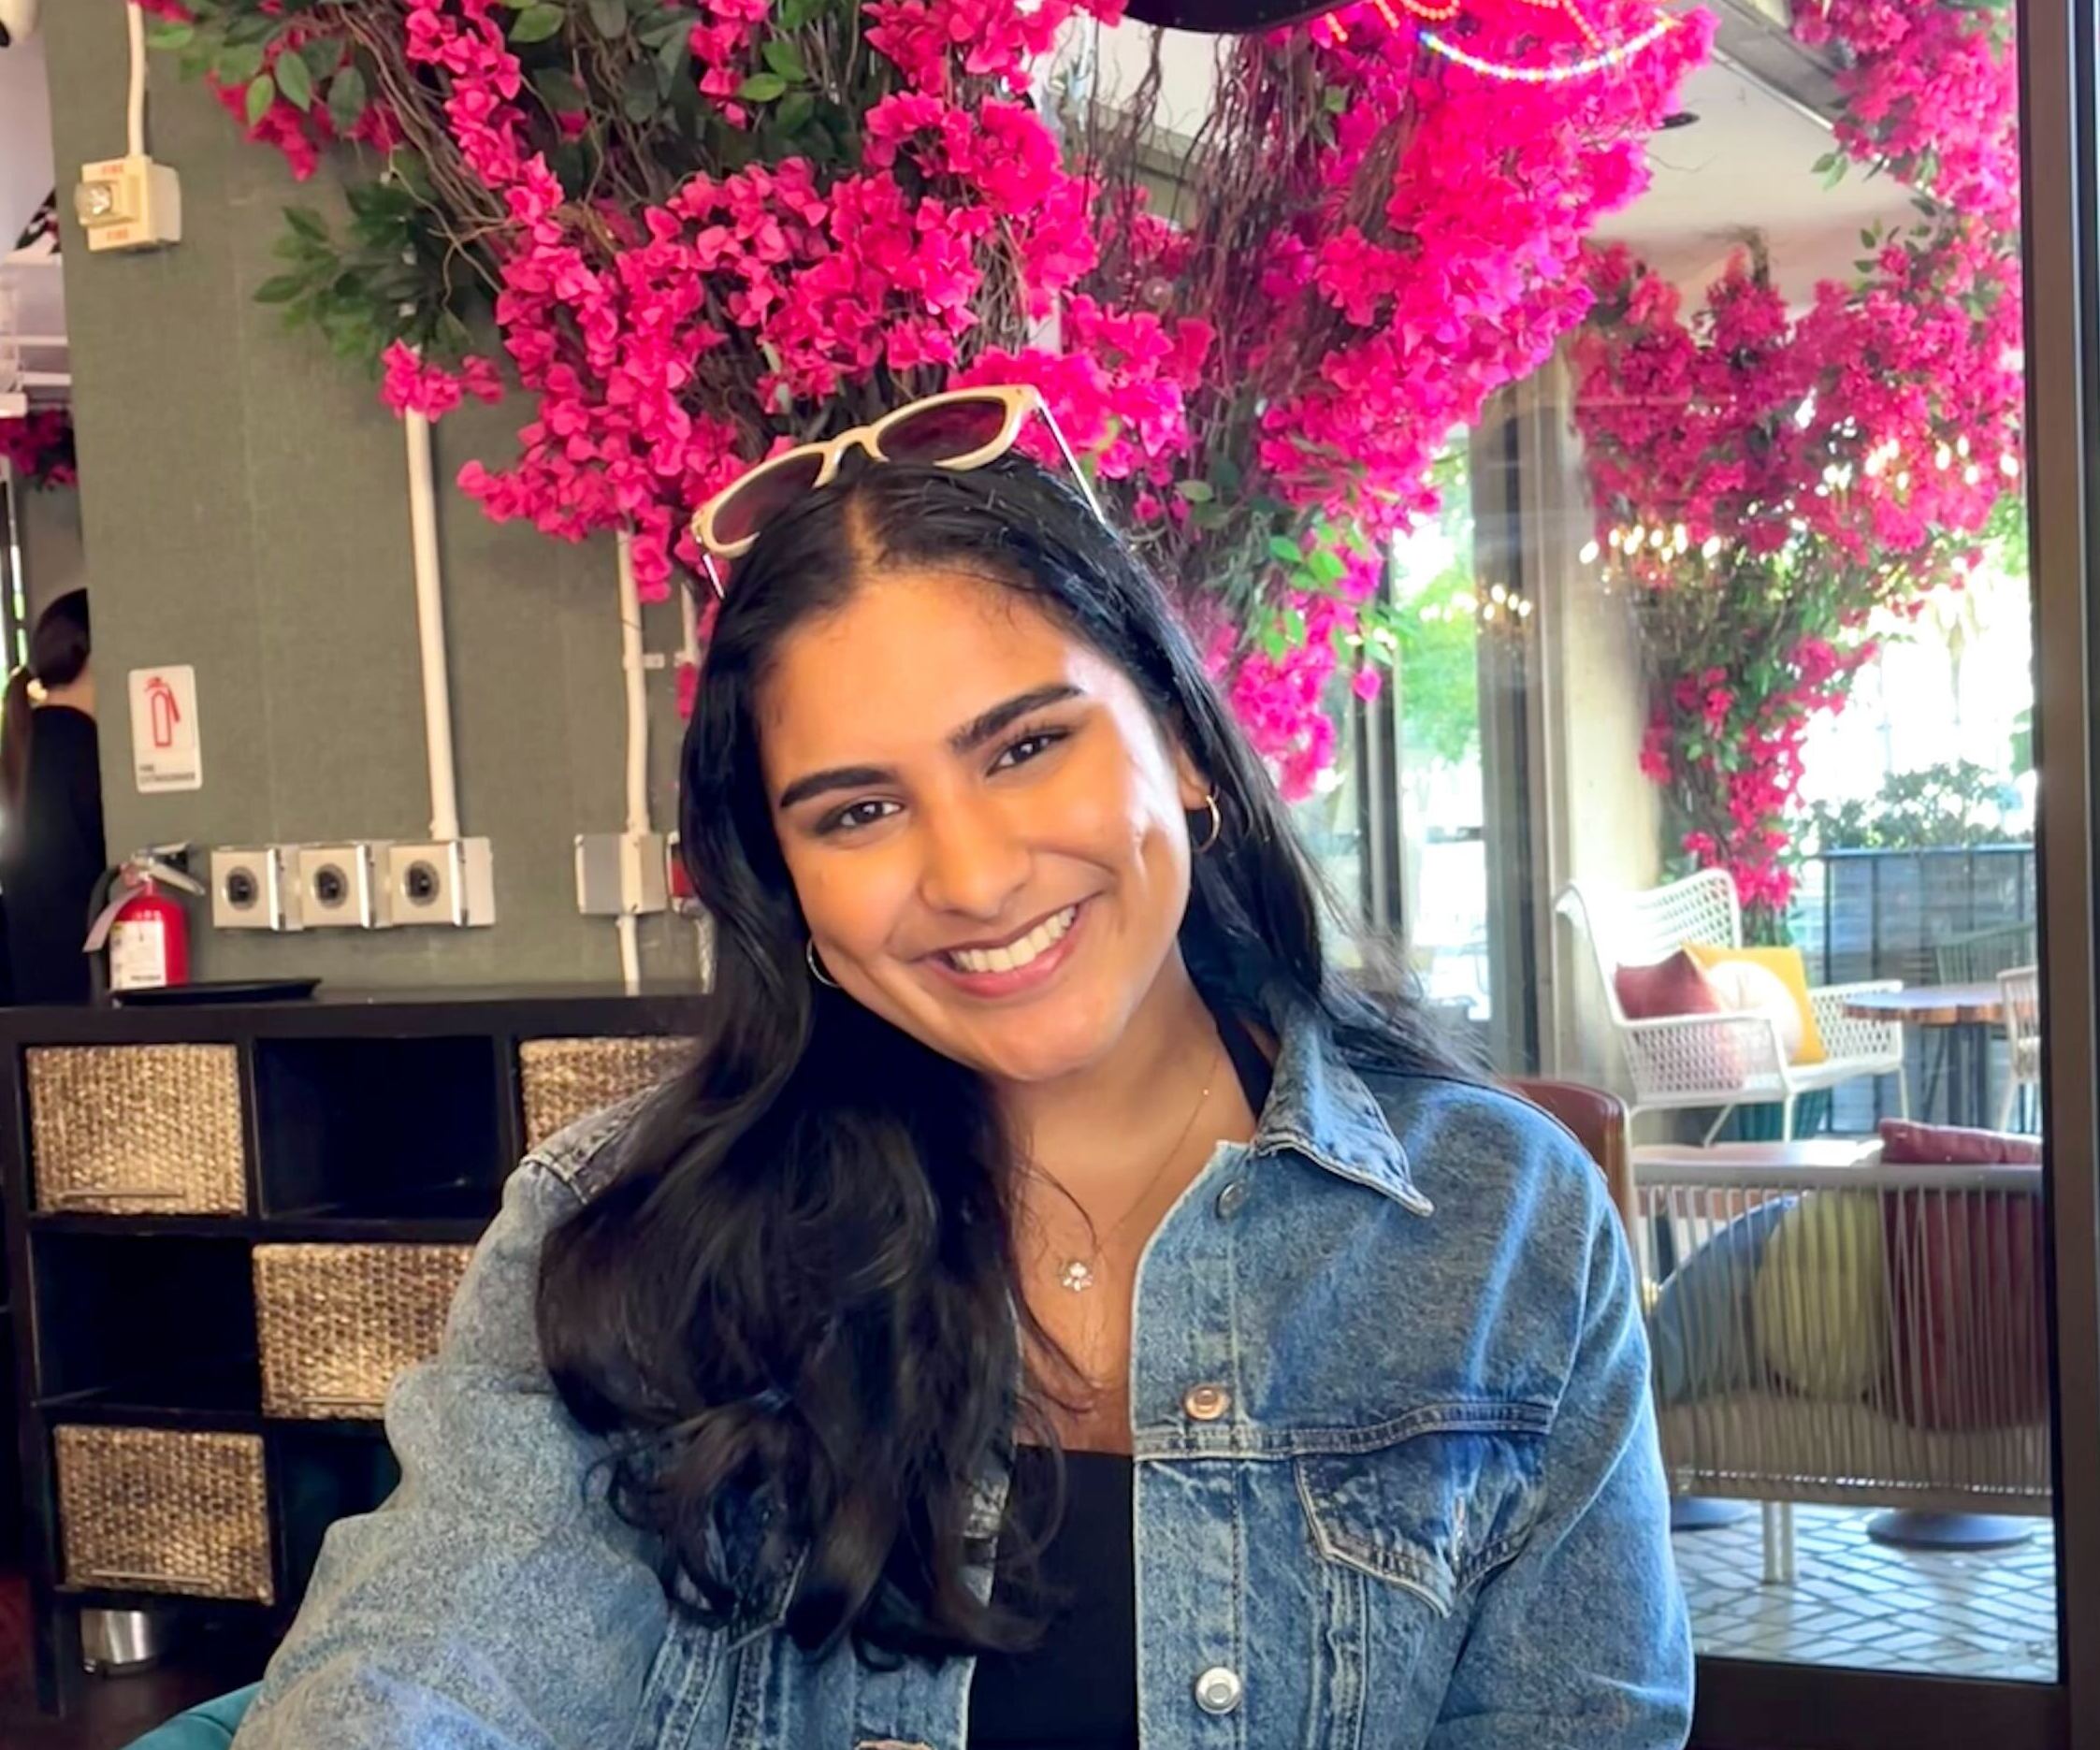
Shalika Neelaveni is a Mechanical Engineering PhD student in the ARMLab and the recipient of the Stanford Graduate Fellowship. She is interested in exploring smart materials for applications in power, sensing, and actuation to improve robot dexterity. Her previous research included developing a soft tactile sensor for soft robotic grippers as an undergraduate researcher at the University of Pennsylvania, under Professor Kevin Turner. Outside of the lab, she loves to aimlessly walk around new cities, lift at the gym, and wear her Crocs.