← All people
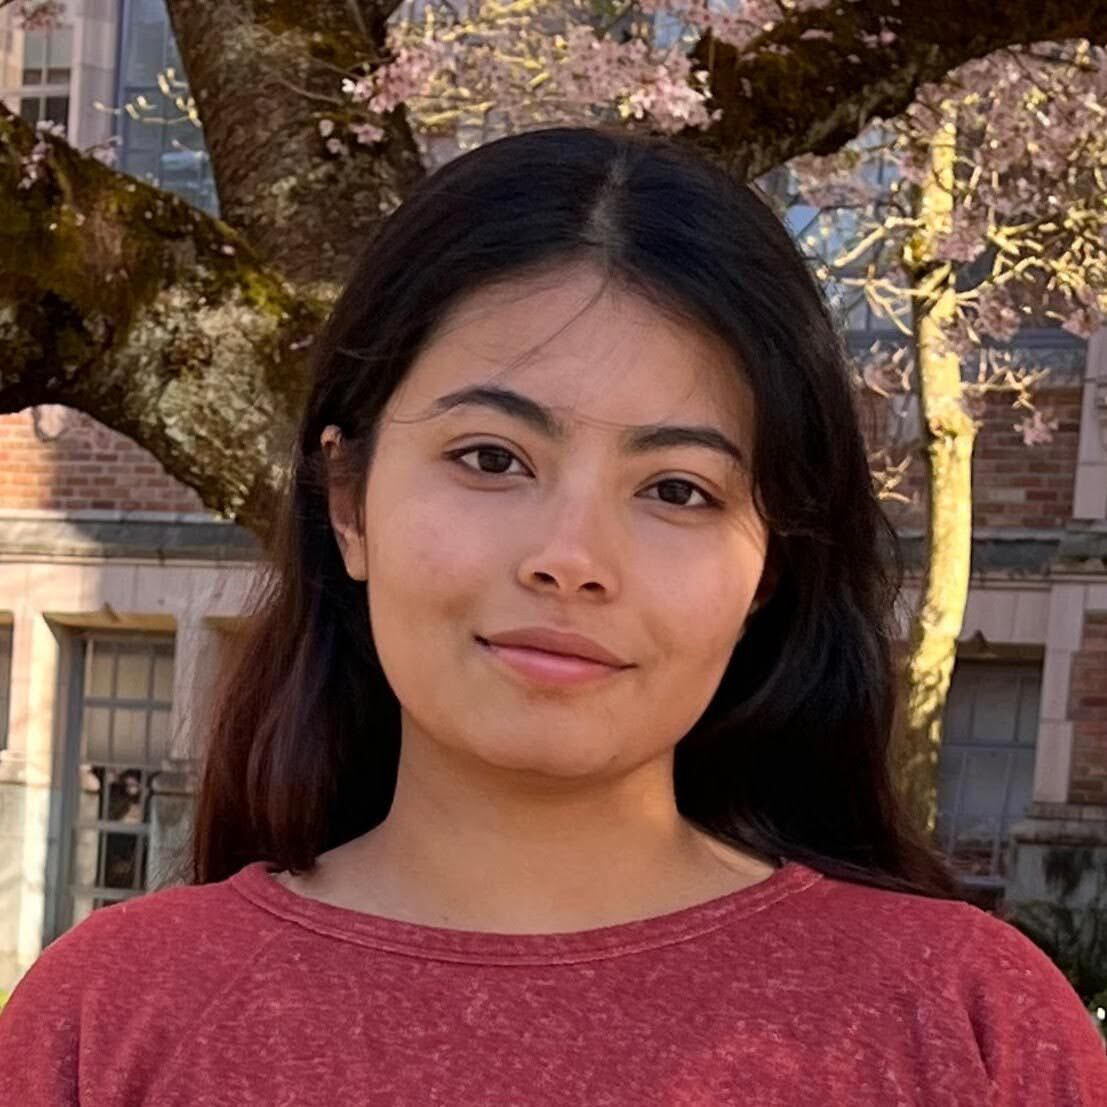
Maisha Khanum is a Ph.D. student in Mechanical Engineering and a recipient of the NSF Graduate Research Fellowship. She is interested in perception-based planning and adaptive control strategies to enhance the functionality of exoskeletons in complex, real-world terrains. She previously worked on icy surface locomotion in the Extreme Environment Robotics Group at JPL and fully actuated robotic hands in the AMBER lab at Caltech. Outside of the lab, Maisha enjoys working on art projects and building knock-off Legos.