Alumni
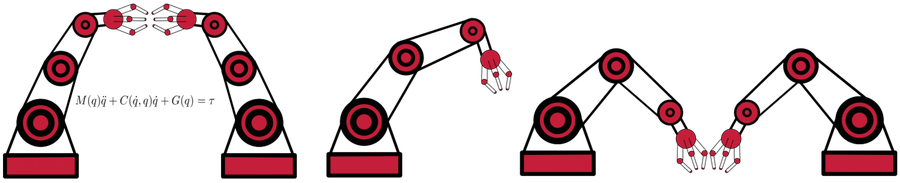
Dexterous Manipulation and Tactile Sensing
worked on teaching robotic dexterity with tactile data in manipulation